Tesseract, a SwRI-developed open source robotic planning software framework, within the ROS-Industrial open source project, provides a flexible and extensible framework for various tasks related to robot motion and manipulation. Current path planners that work with Tesseract (e.g. Trajopt, OMPL, and Descartes) use constraints to generate collision-free paths. However, these current path-planning algorithms are poorly suited for high-degree-of-freedom (DOF) systems and additional planning constraints must be considered within the Tesseract framework to properly plan for a collaborative multi-arm system. As such, a significant portion of this internal effort involved implementing additional tools and constraints to plan trajectories for multiple robots simultaneously. We added constraints centered around multiple robot control, parameterized by the object being manipulated and the task being performed.
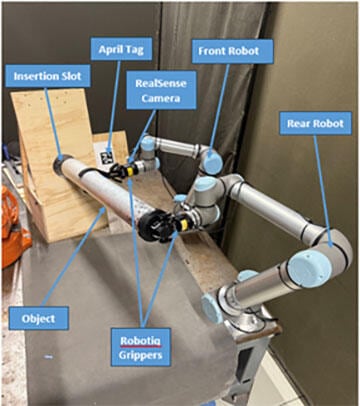
The manipulation of heavy and bulky objects is a challenging endeavor in the field of robotics. These tasks often necessitate the use of large robots with high payloads and substantial power requirements. In our latest research, we have tackled this problem by developing a multi-arm, force-feedback system specifically designed for the intricate and high-stakes application of loading munitions for military applications. Our focus has been on creating a more efficient and reliable method to handle these heavy-duty tasks, with a particular emphasis on improving object alignment and insertion precision. In this article, we highlight ARMATRIX, an internal research project to determine the viability of a specific multi-purpose approach to bulky object manipulation through a multi-arm system.
Finally, for the Object Insertion Task, rather than requiring a known insertion distance, we aim to use a Cartesian force controller to command the rear robot to exert a force on the insertion object along a vector normal to the insertion surface. Insertion would be completed when the rear robot feels an average force greater than or equal to the applied force in the negative direction of insertion for three seconds. This indicates that the object had been completely inserted into the insertion tube. The duration and force were chosen to elevate the force feedback felt during insertion above the noise floor of the F/T sensor, allowing greater confidence the object had been successfully inserted.
Looking forward for the Free Space Movement Task, we anticipate integrating admittance control with the joint trajectory controller. Admittance control is a control strategy used in robotics to regulate the behavior of a robot when interacting with external forces. Here, it will introduce compliance to the forward robot as it moves along its planned trajectory, allowing dynamic coordination between the two robots (e.g. if the rear robot was behind on its trajectory, the forward robot could adjust accordingly). This enhancement aims to mitigate the impact of latency and ensure synchronicity between the dual-arm robotic system during execution, improving the overall performance and reliability.
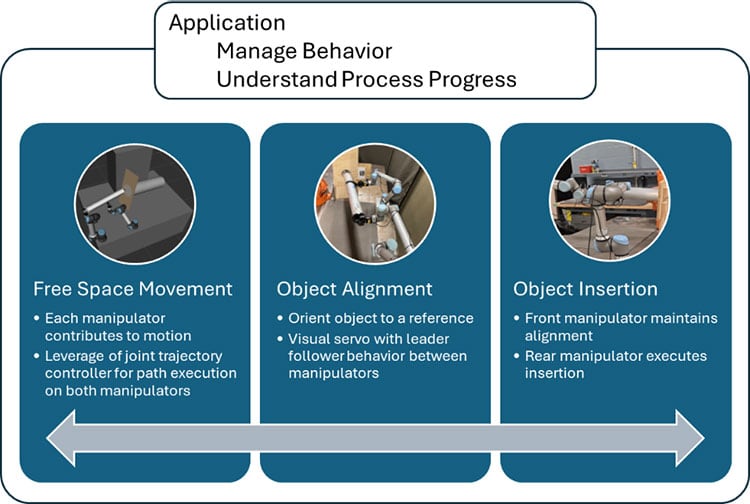
Visual servoing is a control technique in robotics that uses visual data from cameras to guide a robot’s movements. It relies on feedback from the robot’s visual sensors to adjust its position and orientation in real time to achieve a desired goal, defined with respect to a visual marker (e.g. an April tag). A Cartesian motion controller commands the forward robot, equipped with an external camera, to align a defined camera frame with a tag frame and ultimately drive the system toward the insertion surface and align the insertion object with the insertion point. During visual servoing, the rear robot is also commanded by a Cartesian motion controller to follow the forward robot.
For the Object Insertion Task, we adopted a holder-manipulator control strategy, where one manipulator is primarily responsible for holding the object, acting as a dynamic rig, while the other manipulator maneuvers the part. The front robot acts as a holder and is responsible for maintaining visual alignment through visual servoing. The rear robot, also using a Cartesian motion controller package, served as the manipulator to push the object into the slot a known distance. This bifurcated yet cooperative setup allowed the front robot to ensure proper alignment while the rear robot executed the insertion, resulting in better insertion outcomes.
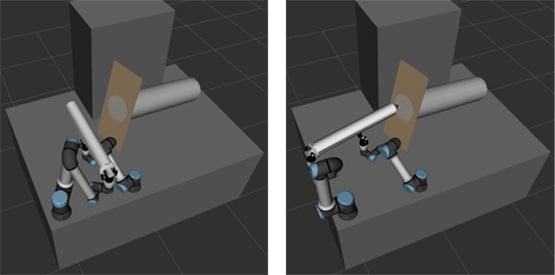
To execute the Free Space Movement Task, we leveraged a combination of SwRI-developed products and industry-standard software packages. We used Tesseract to plan free space trajectories for the 12-DOF (Degrees of Freedom) kinematic chain, where descartes_light generates potential trajectories for each manipulator and a discrete contact check determines which trajectories are valid for the dual arm system. For the execution of these planned trajectories on the hardware, we utilized the ros2_control from the Robot Operating System (ROS), which enabled us to employ the joint trajectory controller effectively.
This work implemented multi-robot coordination and planning strategies to achieve manipulation and assembly tasks that cannot be easily performed using a single robotic arm. Visual servoing was added into the control scheme of the front and the back robot, to increase the robustness and repeatability of the alignment process. Additionally, this project added a fixed distance between manipulators and segmentation of the high-DOF system into smaller sub-pieces as new constraints to enable the use of the SwRI developed Tesseract framework for multi-robot trajectory planning.
In conclusion, our development of a multi-arm, force-feedback system marks a significant advancement in the field of robotic manipulation of heavy and bulky objects. While there is still work to be done to perfect our system, our results demonstrate a promising step towards more efficient and reliable robotic solutions for complex industrial applications like munitions loading. We are excited about the potential applications of this research and look forward engaging with government and industry to extend this capability for their applications.
For the Object Alignment Task, we aim to implement a master-follower with force-control coordination strategy, where one manipulator is primarily responsible for the manipulation of the object while the other manipulator follows course and maintains a zero-force differential. Using zero-force control, the rear robot will react to an external force by adjusting its movement to maintain a zero-force state. In our system, the rear robot will feel the applied forces from the forward robot moving toward the insertion surface and follow along.
资料来源:企业官网公司介绍页面(复核日期:2026-10-29)。